Quadratic Form
Definition
A quadratic form on is a function of the form
where is a real matrix and a column vector. Equivalently, is a polynomial in whose terms all have degree exactly two (a homogeneous polynomial of degree two, the zero polynomial included, which comes from ). The matrix can always be chosen symmetric, and the symmetric choice is unique: it is called the matrix of .
Interpretation
A quadratic form is the many-variable version of : every term has degree exactly two, so , and a symmetric matrix stores the coefficients. The main question about a quadratic form is its sign in different directions.
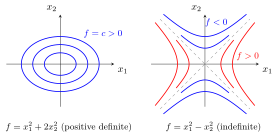
The figure shows curves on which the form is constant. For , with matrix , they are nested ellipses: the value is positive in every direction. For , with matrix , they are hyperbolas: the form is positive near the -axis, negative near the -axis and zero on the dashed lines . Because , the sign is the same along each line through the origin, apart from the origin itself.
The shading shows over the plane: colour for positive values, the other colour for negative ones. Change the entries of the symmetric matrix and drag .
Change , , and turn the surface: the sign of in each direction shows up as a bowl, a cap, a saddle, a ridge or trough with a flat direction, or the flat plane for the zero form.
The transpose turns the column vector into a row, so the matrix products in have sizes , and and produce a number. For and a symmetric , expanding gives : the diagonal entries are the coefficients of the squares, and each off-diagonal entry carries half of a mixed term.
Sorting forms by their signs gives the definiteness of the matrix. Quadratic forms return in calculus of several variables, where the second-order term of a Taylor approximation is a quadratic form in the displacement.
A common slip is to put the whole coefficient of a mixed term into the matrix. The form has the symmetric matrix ; the matrix would give .
Key Results
- Different matrices can give the same form: for , because . The symmetric matrix is the only symmetric one with this form.
- In terms of the symmetric matrix, the coefficient of is and the coefficient of () is .
- Quadratic forms are used to define definiteness of symmetric matrices.
Examples
- If , then .
- For , .
- has the symmetric matrix ; the non-symmetric gives the same form.
Prerequisites
Related Concepts
- Eigenvalue and Eigenvector
- Inner Product
- Normal Distribution
- Variance and Standard Deviation
- Symmetric Matrix
- Definiteness and Eigenvalues
Sources
- Math II: Linear Algebra · Week 6
- Math III: Analysis · Lecture 7
Aliases: homogeneous quadratic polynomial Symbols: real numbers, sum
Last updated: 27 October 2026 11:52
Quadratic FormDefinite MatrixBordered Matrix TestHessian MatrixQuadratic Form on a Constraint SetTensor Contraction for Taylor TermsMatrix ProductTransposeVectorEigenvalue and EigenvectorInner ProductNormal DistributionVariance and Standard DeviationSymmetric MatrixDefiniteness and Eigenvalues