Unrestricted Variable Transformation
Definition
An unrestricted variable can be replaced everywhere by the difference of two nonnegative variables:
If is required, use with instead.
Interpretation
The simplex method works with nonnegative variables only, but some decisions can be negative, for example a change in stock level. The transformation writes such a free variable as the difference of two nonnegative parts, so the model again has only nonnegative variables while the original variable keeps its full range.
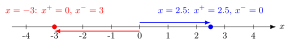
On the number line, is written with and , and with and . One part carries the size of the number and the other is zero, so holds with both parts nonnegative.
The substitution has to be made in the objective and in every constraint; afterwards no longer appears, and its value is recovered as . The representation is not unique: can also be written as . This does no harm: the objective and constraints depend on the two parts only through their difference, so all representations of the same are equally feasible and give the same objective value. Both parts stay linear terms, so the model remains a linear program.
When the sign is known, splitting is unnecessary: for the single substitution is enough, and a variable that already satisfies a nonnegativity constraint needs no change. With the negative RHS transformation and the minimization-to-maximization transformation, it is one of the steps that bring a model into the form the simplex method starts from.
Key Results
- Apply the substitution to both the objective and every constraint.
- The difference representation is not unique; it is not necessary to impose a nonlinear restriction preventing both parts from being positive.
- The optimal original variable is the difference of the computed parts.
Examples
The two replacement columns are opposites: the column of is times the column of . They cannot both be basic in the same basic solution, although a feasible solution that is not basic may have both parts positive.
- and give .
- The other-model-forms exercise transforms its nonpositive as .
Prerequisites
Related Concepts
Sources
- OR Modelling · Week 2
Aliases: variable splitting
Last updated: 20 October 2026 03:02
Unrestricted Variable TransformationNonnegativity ConstraintLinear ProgrammingAugmented FormMinimization-to-Maximization Transformation