Plane
Definition
A plane is a two-dimensional geometric object described by a point and two linearly independent direction vectors as .
Interpretation
A plane is a flat two-dimensional surface: from a starting point one can move in two independent directions, and every point is reached by choosing how far to go in each. The parameters and are these two amounts, and the displacement is a linear combination of the direction vectors.
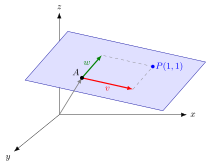
In the figure the plane passes through and contains the directions and . The choice gives the corner of the dashed parallelogram. Other values of and , negative ones included, fill the rest of the plane.
The parametrization needs linearly independent and . If the directions are linearly dependent, the formula describes at most a line; if both are zero, it gives only the point . The description is not unique: may be any point of the plane, and any two independent direction vectors parallel to it. A plane through the origin is the span of and , a two-dimensional subspace; any other plane is such a subspace shifted by .
In a plane can also be described by a single equation, the point-normal equation with a normal vector. In , the one-equation description gives a hyperplane.
A common slip is to read and as points of the plane. They are directions: and lie on the plane, while itself does so only when the plane passes through the origin.
Key Results
- Three non-collinear points determine a plane.
- If two direction vectors are scalar multiples, they do not determine a unique plane.
Examples
- is the -plane.
- The plane through three non-collinear points can be written .
Prerequisites
Related Concepts
Sources
- Math II: Linear Algebra · Week 5
Keywords: affine plane, two-dimensional flat Symbols: real numbers
Last updated: 27 October 2026 11:52
PlaneNormal VectorPoint-Normal Equation of a PlaneLinear Dependence and IndependenceLinear CombinationVectorParametric Representations of Lines and PlanesHyperplaneAffine MapSkew Lines