Method of Lagrange for Inequality-Constrained Maximization
Theorem
Let be open, and let be continuously differentiable. Consider
The course convention writes and defines
If is a local constrained maximizer, then either nondegenerate constraint qualification (NDCQ) fails or there exists such that
The condition is complementary slackness.
Interpretation
Inequality constraints are directional, so multiplier signs and slackness matter. At a maximizer each constraint is either slack, and plays no role nearby, or binding, and acts as a one-sided equality. The sign condition and complementary slackness handle both cases.
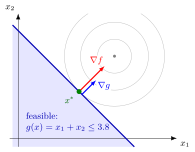
The unconstrained maximum of , the centre of the grey level circles, lies outside the shaded feasible side of , so the constrained maximum lies on the line. There the gradient and point the same way, outwards towards the infeasible peak, so with : could only increase outside the feasible set.
Drag the peak of : if it is feasible the constraint is slack and ; otherwise the optimum sits on the line and with .
The sign condition encodes this direction. If were a negative multiple of , it would point into the feasible set, and a small step inwards would increase . Complementary slackness says that each constraint is binding or has . NDCQ is checked for the binding constraints only.
The conditions are necessary only. For subject to from the Examples, both with and with satisfy them. The first is a saddle point of . The second is a local maximizer but not a global one: grows without bound along the feasible points , .
Compared with equality constraints, whose multipliers may have either sign, these two conditions are new. Linear programming shows the same pattern: a resource with unused slack has shadow price .
Key Results
- A binding constraint satisfies .
- A nonbinding constraint has zero multiplier by complementary slackness.
- The theorem gives necessary, not sufficient, conditions.
Examples
- For subject to , the Lagrangian is .
- If no inequality is binding at a local maximum, all inequality multipliers are zero and the unconstrained stationarity condition returns.
Prerequisites
Related Concepts
Sources
- Math IV: Multivariate Calculus · Week 5, Lecture 1
Keywords: inequality FONC for maximization, KKT necessary conditions for max Symbols: element of, infinity, lambda, nabla gradient, real numbers, subset, sum
Last updated: 22 October 2026 19:04
Method of Lagrange for Inequality-Constrained MaximizationKuhn-Tucker Conditions with Nonnegativity ConstraintsMethod of Lagrange for Mixed ConstraintsParametric Constrained Optimization ProblemNondegenerate Constraint QualificationLagrangian FunctionLagrange Multiplier