Change of Basis
Definition
Let be an ordered basis of , the new basis, and let be the standard basis. The transformation matrix of is the matrix whose columns are the new basis vectors,
transforms the standard basis into the new basis, , and transforms it back. It is invertible because its columns form a basis.
The coordinate vector of with respect to is the vector of the unique scalars with . In matrix form,
Interpretation
The vector does not move; only its description changes. The columns of say where the new basis vectors are, so multiplying new coordinates by rebuilds the vector in standard coordinates, and finds the new coordinates of a vector given in standard coordinates.
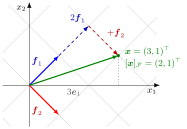
The figure shows the first example. The green arrow is one fixed vector. Along the standard axes it is ; along the tilted grid of it is . Changing basis only changes which grid the vector is read on, so its coordinates change from to .
Drag , or : the arrow stays the same while its description changes, from in the standard basis to along the grid of . Switch on the operator to follow as well.
The direction is the usual source of errors. takes the standard basis vectors to the new ones, but on coordinates it works the other way round: it turns new coordinates into standard coordinates . Going from standard to new coordinates needs the inverse . Other textbooks call such a matrix a change-of-basis or transition matrix and may attach it to either direction, so check which direction is meant.
Changing basis also changes the matrix representation of a linear map. For an operator on the result is a similarity transformation; choosing an eigenbasis makes the matrix diagonal.
Key Results
- Every invertible matrix is the transformation matrix of the basis formed by its columns.
- If is the matrix of a linear operator in standard coordinates, its matrix in the new basis is : translate new coordinates to standard ones with , apply , translate back with .
- Between two new bases and with transformation matrices and : .
- If is orthonormal, then and .
Examples
Coordinates. In let and , so
For ,
and indeed .
An operator. Let in standard coordinates. Then and
In the new basis the map stretches the first coordinate by and leaves the second alone: is an eigenbasis, and this is a diagonalization of .
Prerequisites
Related Concepts
- Similarity Transformation
- Gram-Schmidt Algorithm
- Diagonalization
- Eigenbasis
- Orthonormal Basis
- Orthogonal Matrix
Sources
- Math V: Advanced Linear Algebra · Week 6
Aliases: basis transformation, change of coordinates, transformation matrix, basis change Keywords: coordinate vector, change-of-basis matrix, change-of-coordinates matrix, x = Fy, F^{-1}x, F^{-1}AF Symbols: real numbers
Last updated: 22 October 2026 19:04
Change of BasisSimilarity TransformationBasisCoordinateInverse and Singular MatricesMatrix Representation of a Linear MapGram-Schmidt AlgorithmDiagonalizationEigenbasisOrthonormal BasisOrthogonal Matrix