An inverse matrix exists only for square nonsingular matrices. The condition AAIA=A keeps only what is needed to solve equations: whenever b=Ax is reachable, AIb is a vector that A maps back to b, because A(AIAx)=Ax.
Because one equation is a weak requirement, a generalized inverse is in general far from unique, and the notation AI means "some generalized inverse". Adding the three further Penrose conditions singles out one of them, the Moore-Penrose inverseA+. A common mistake is to assume properties of A+, such as symmetry of AAI, for an arbitrary AI.
One-sided inverses are special cases: if LA=In (left inverse, full column rank) then ALA=A; likewise for a right inverse.
Existence: every matrix has a generalized inverse. If A=P(IrOOO)Q with P,Q invertible, then the generalized inverses are exactly Q−1(IrYXZ)P−1 with X,Y,Z arbitrary.
Uniqueness: AI is unique if and only if A is square and invertible, and then AI=A−1.
AAI and AIA are idempotent, rank(AAI)=rank(AIA)=rankA, and rankAI≥rankA.
Consistency: Ax=b has a solution if and only if AAIb=b.
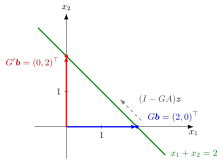
General solution: if the system is consistent, its solutions are exactly x=AIb+(In−AIA)z,z∈Rn, an affine subspace.
Two different generalized inverses. For G=(1000):AG=(1100) and AGA=(1111)=A. The matrix G′=(0001) works too, and so does 41A, since A3=4A. Note that AG is idempotent but not symmetric.
Solving a system. For b=(2,2)⊤:AGb=(2,2)⊤=b, so the system is consistent. With I−GA=(00−11),
x=Gb+(I−GA)z=(2,0)⊤+z2(−1,1)⊤,
which is the line x1+x2=2. For b=(1,0)⊤:AGb=(1,1)⊤=b, so there is no solution.
The figure draws the consistent example with b=(2,2)⊤. The two generalized inverses G and G′ give different particular solutions, Gb=(2,0)⊤ and G′b=(0,2)⊤, but both lie on the same line x1+x2=2. Adding (I−GA)z=z2(−1,1)⊤ moves along that line, so the choice of AI changes the starting point, never the solution set.
Aliases: g-inverse, generalised inverse, {1}-inverse, inner inverse, 1-inverse
Keywords: A^I, A^-, A A^I A = A, consistency condition, x = A^I b + (I - A^I A) z, conditional inverse
Symbols: element of, real numbers
Last updated: 22 October 2026 19:04
Generalized InverseMoore-Penrose InverseMatrix ProductRankInverse and Singular MatricesLeft and Right InversesLeast SquaresAffine SubspaceIdempotent Matrix